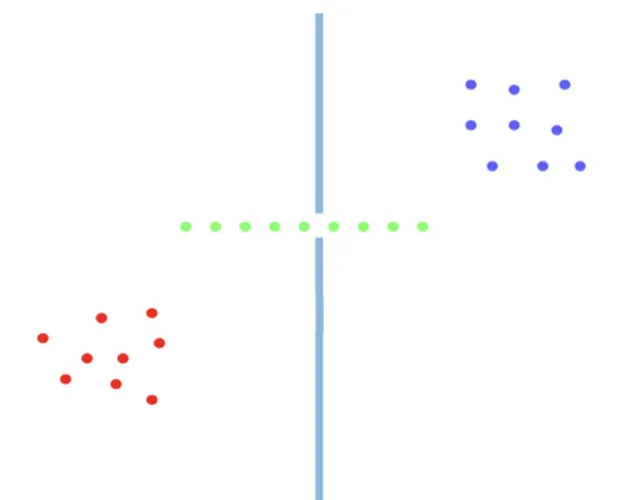
Swarm control for a flock of drones
Getting nine drones from A to B through a gap only one can fit, with no collisions, using gradient descent and artificial potential fields.
- Year
- 2017
- Context
- Final-year engineering project, Loughborough University
- Tools
- MATLAB, Gradient descent, Potential functions, Swarm intelligence

The aim
Move a flock of drones between two points, through an aperture too narrow for the formation, without any collisions. The flock should keep its formation on either side.
Approach
Several swarm-intelligence methods were researched first: ant colony optimisation (ACO), particle swarm optimisation and honey-bee algorithms. ACO builds solutions from simulated pheromone trails that strengthen on good paths and fade on poor ones. It suits route-finding, but continuous, real-time collision avoidance needs something else.
The final controller combines gradient descent with artificial potential functions. The goal attracts each drone, while walls and other drones repel it. Each drone follows the steepest descent of the combined field, so the swarm finds its own way through the gap.
Results
- Nine drones simulated in MATLAB, for about 90 seconds in 2D and 60 seconds in 3D.
- The flock moves as a cluster, narrows into single file, passes through the aperture, then re-forms on the far side.
- Zero collisions in both runs.
Why it matters
The same ideas power warehouse robots, delivery fleets and search-and-rescue drones. They let many machines share space safely with no central controller.